
HARCO Lab Participated in ICCAS 2026
Members of HARCO Lab participated in the 2026 International Conference on Control, Automation and Systems (ICCAS 2026), held in Sapporo, Japan, from October 27 to 30, 2026.
Jungsoo Lee and Jaegyun Park attended the conference and presented the lab’s recent research on LLM-driven autonomous robot navigation, spatial reasoning, and semantic understanding.
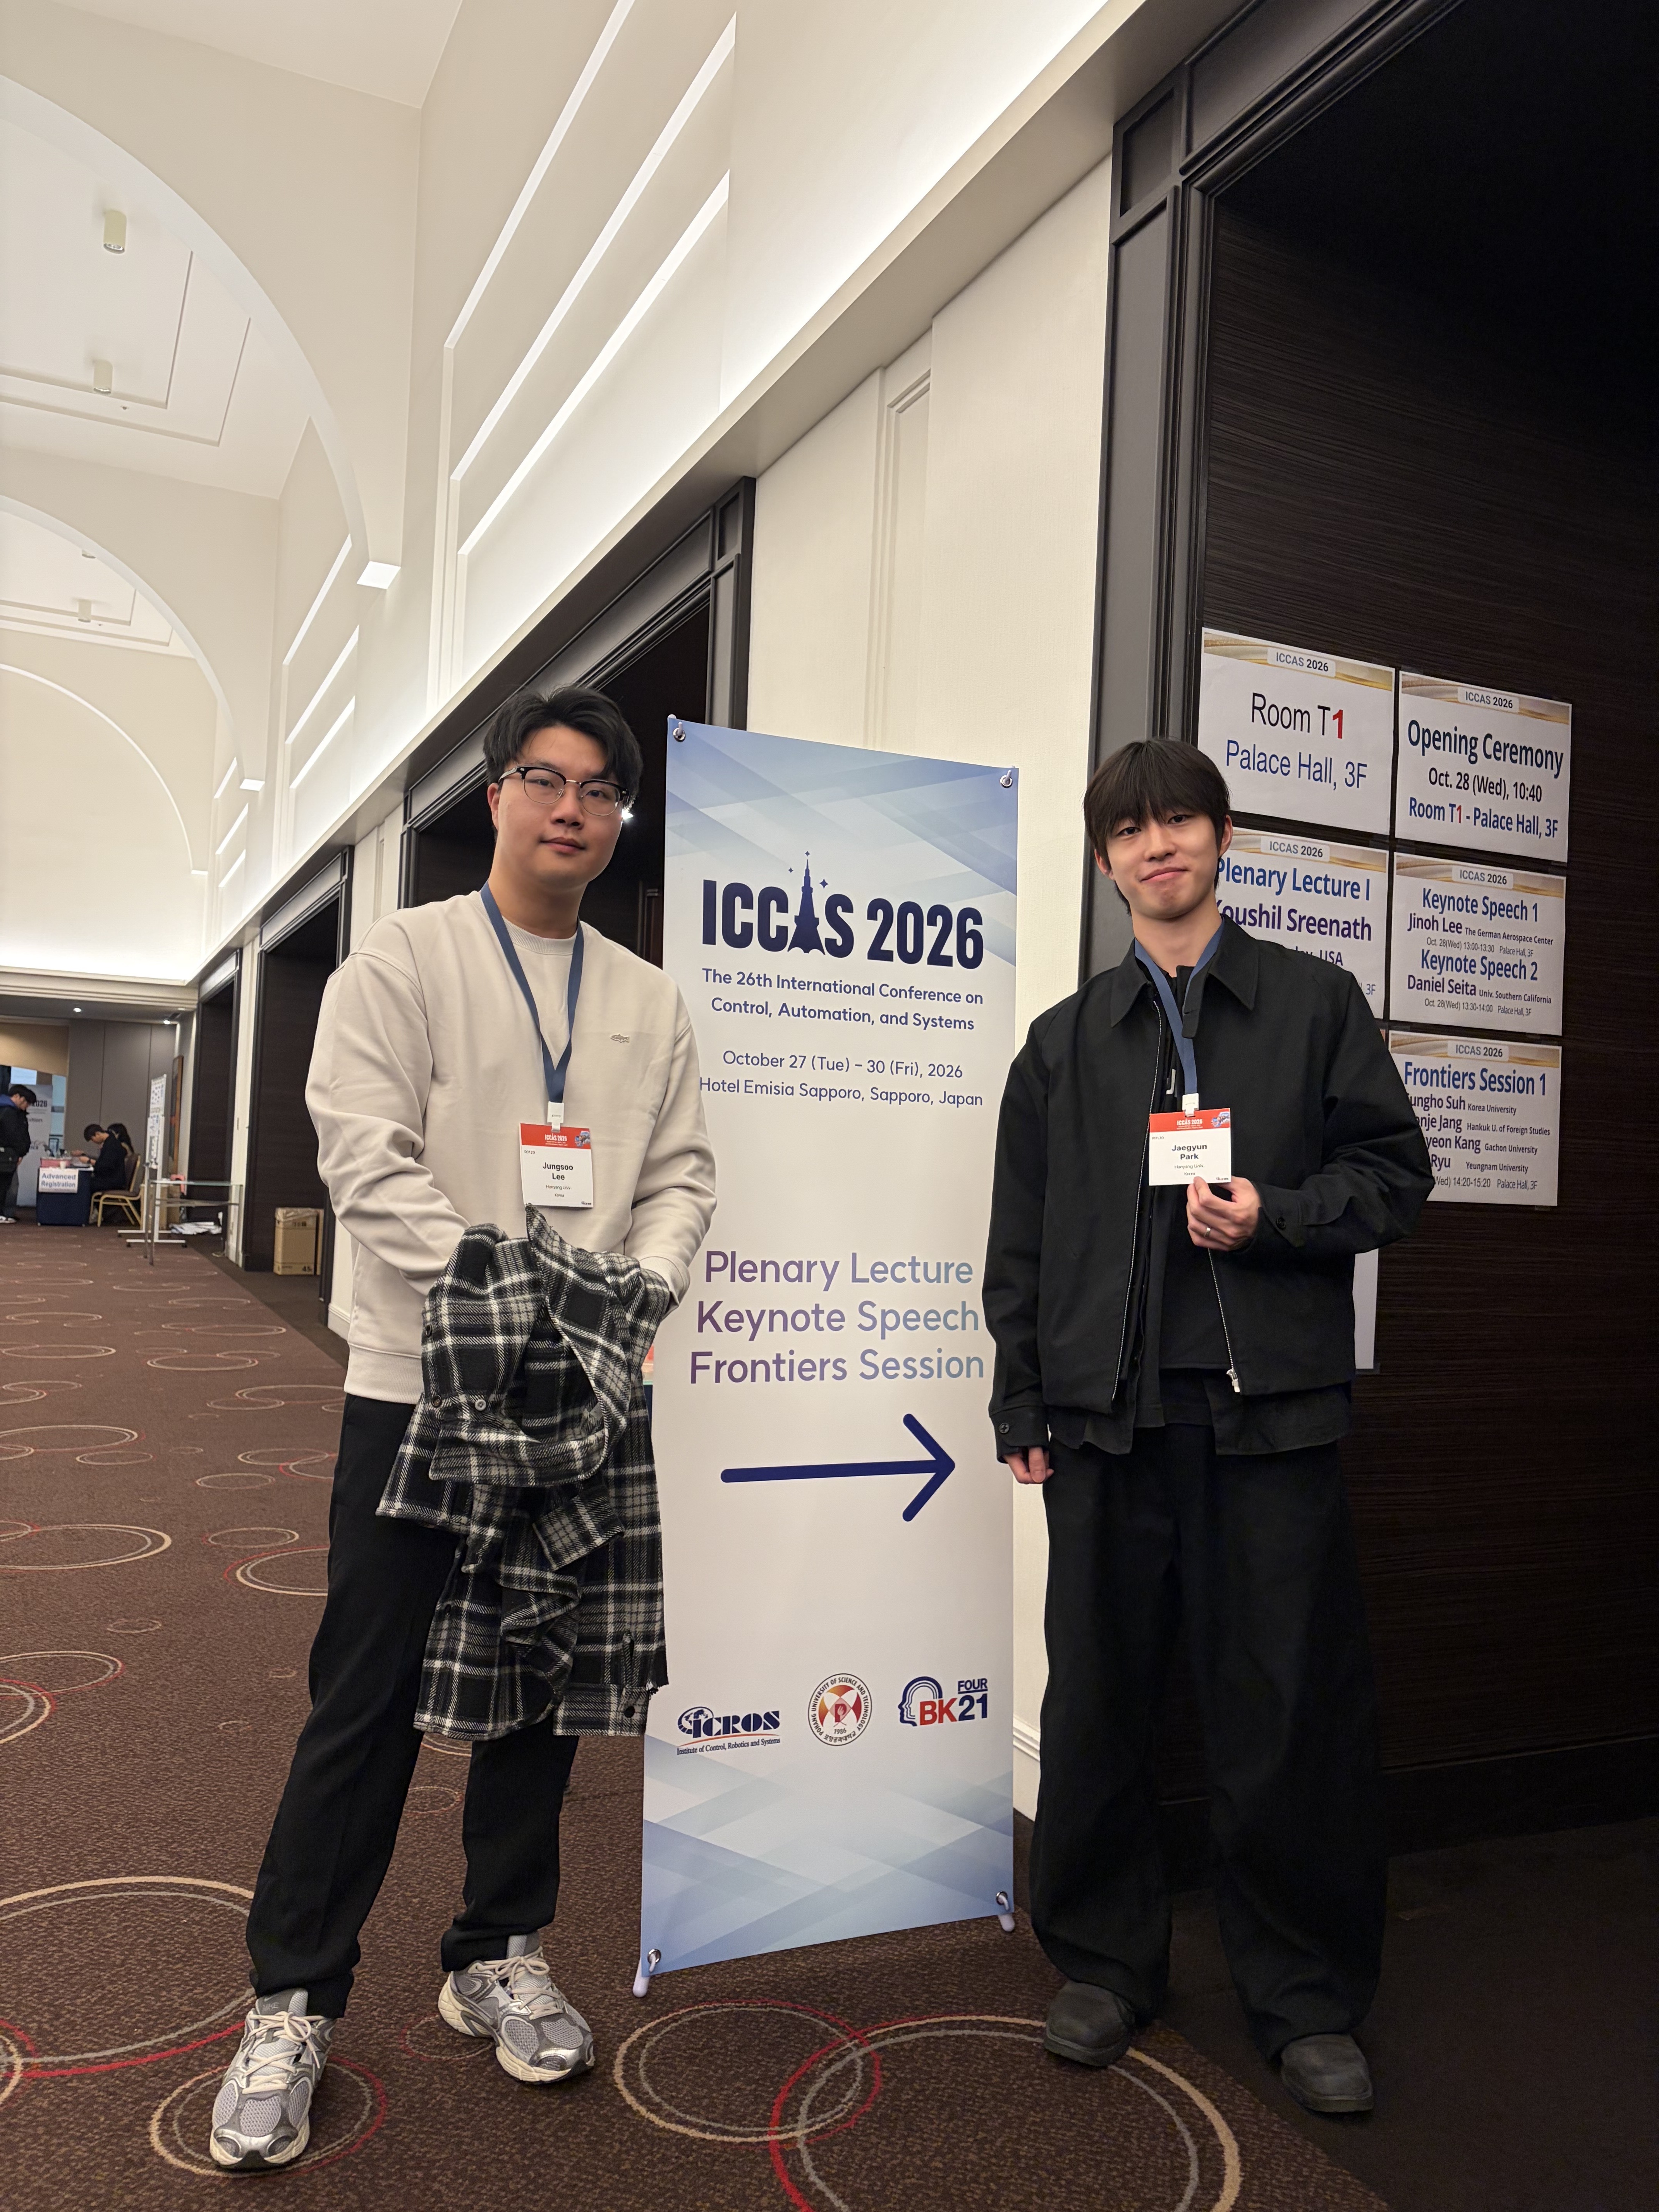
ICCAS 2026 brought together researchers and engineers in control, automation, robotics, and artificial intelligence, providing an opportunity to share recent advances in intelligent robotic systems.
Research Presentation
■ Spatial and Semantic Reasoning for LLM-Driven Robot Navigation via MCP
Authors: Jungsoo Lee, Jaegyun Park, and Wansoo Kim
Affiliation: Hanyang University, Republic of Korea
HARCO Lab presented research titled “Spatial and Semantic Reasoning for LLM-Driven Robot Navigation via MCP.”
The study proposes a framework that integrates Large Language Models (LLMs) with existing ROS-based robot navigation systems using the Model Context Protocol (MCP).
The proposed framework enables LLMs to interpret spatial and semantic information, understand natural-language instructions, and determine appropriate navigation targets without modifying the existing ROS navigation architecture.
Experimental results in a simulated indoor environment demonstrated over 97% map coverage during autonomous mapping, along with successful spatial and semantic reasoning-based navigation.
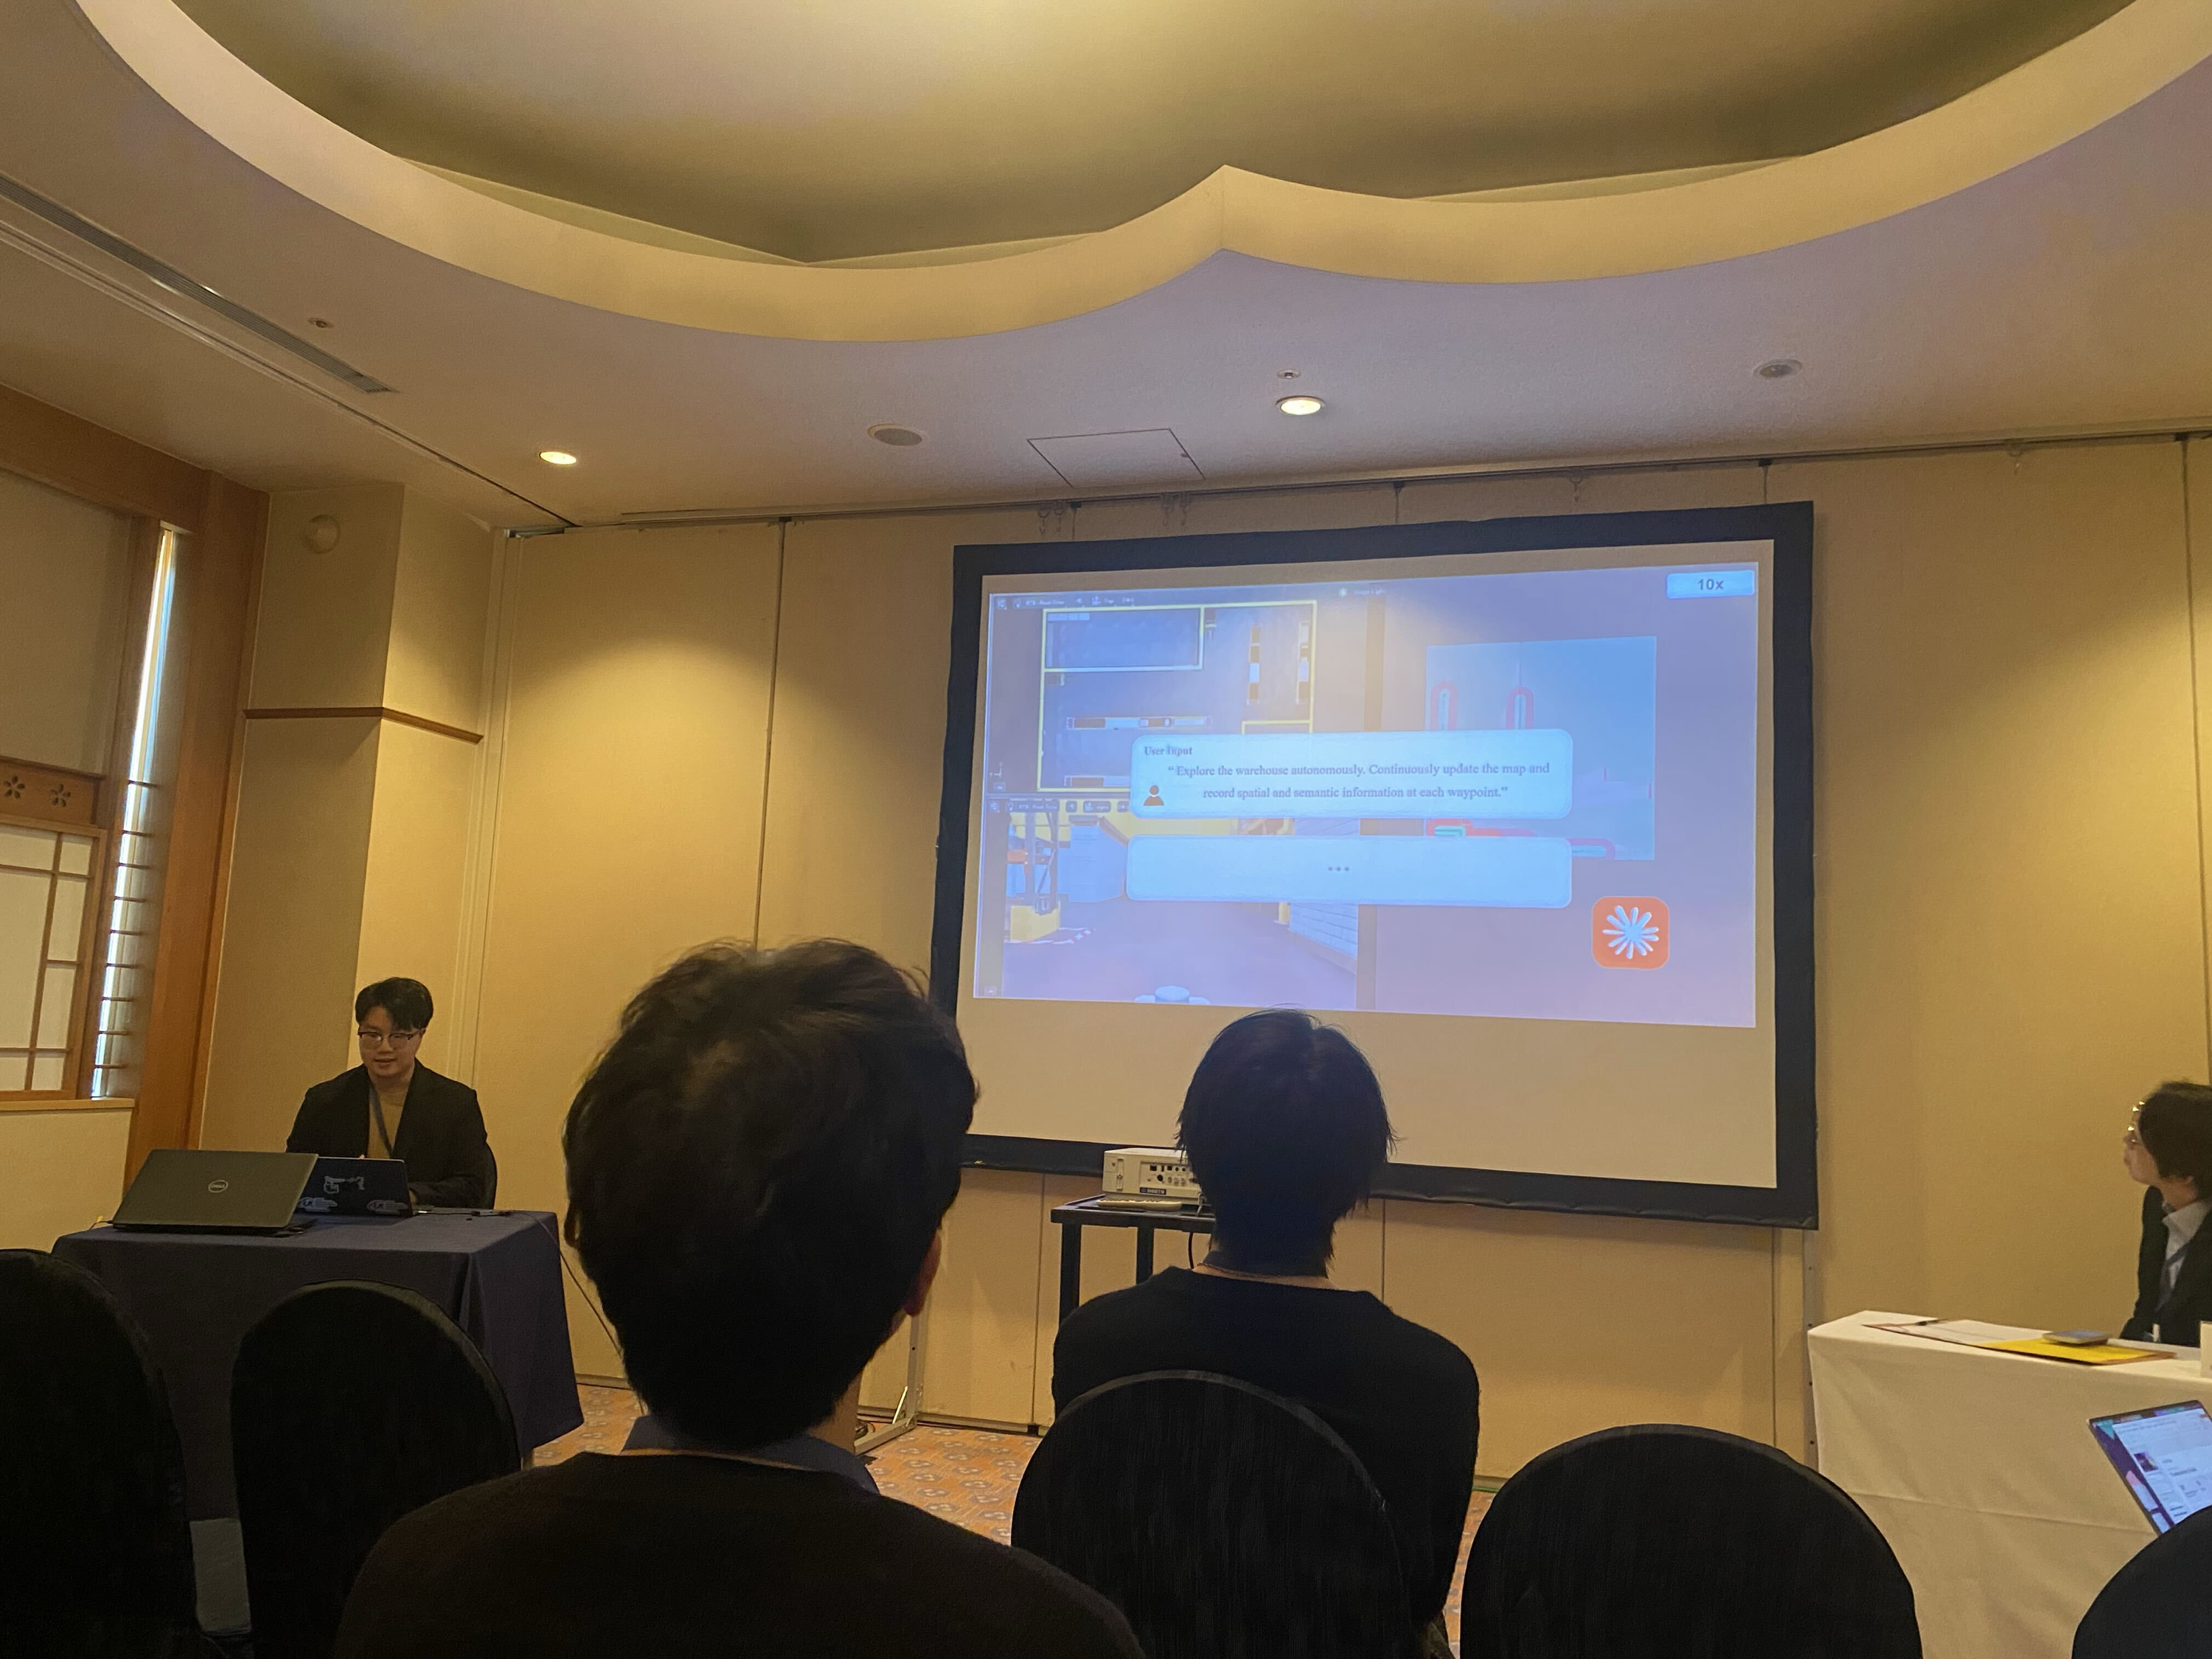
Through participation in ICCAS 2026, HARCO Lab shared its latest research on LLM-based intelligent robot navigation and exchanged ideas with the international robotics community, exploring future directions for autonomous robotic systems capable of understanding and responding to natural-language instructions.